Flight Controller218 views
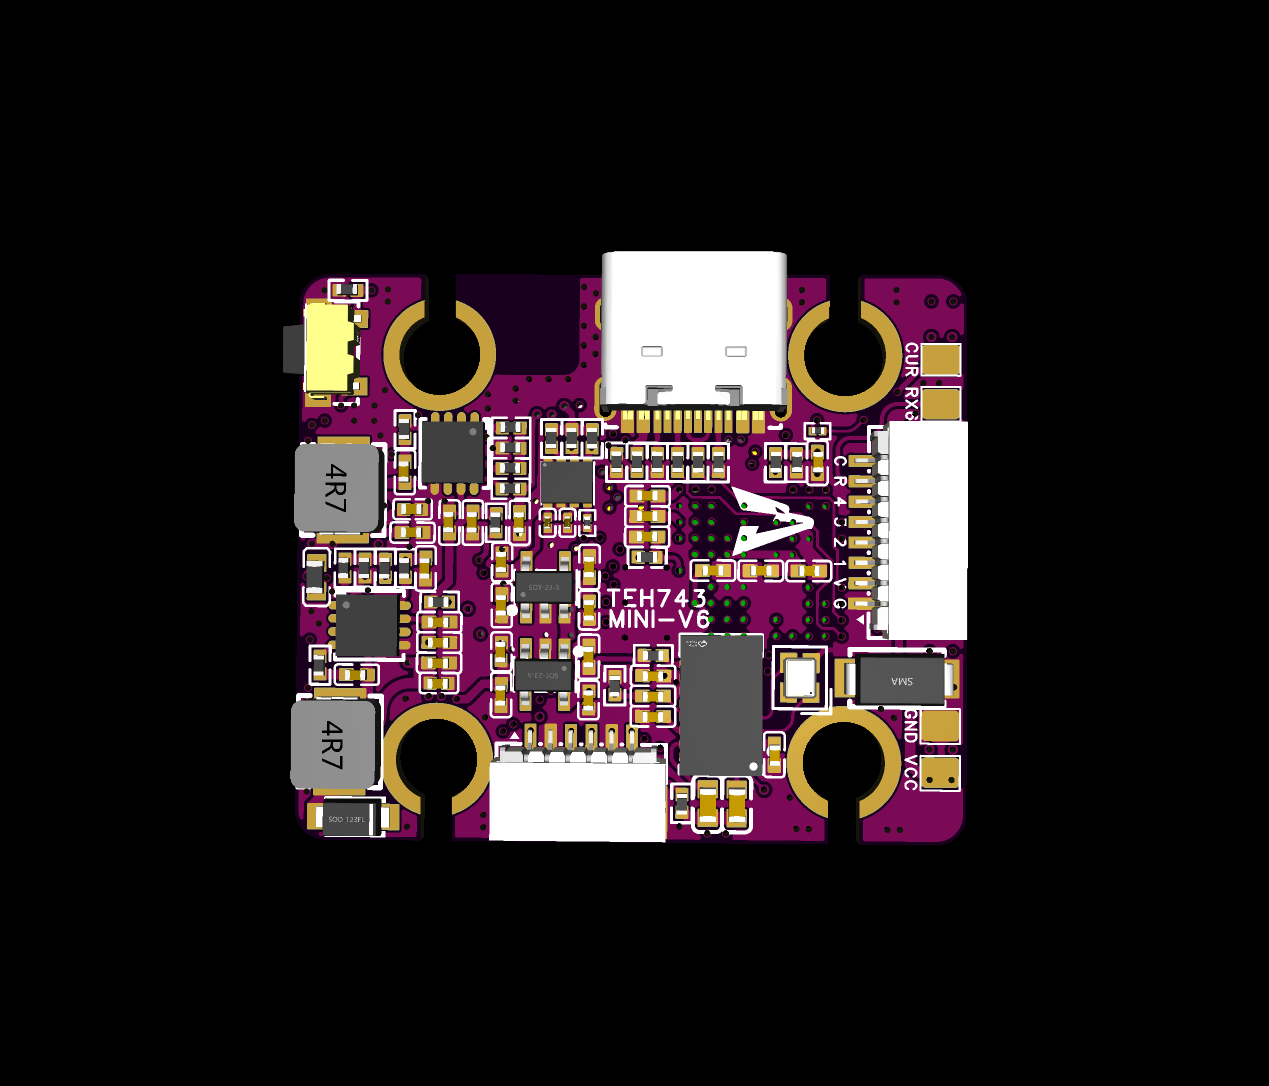
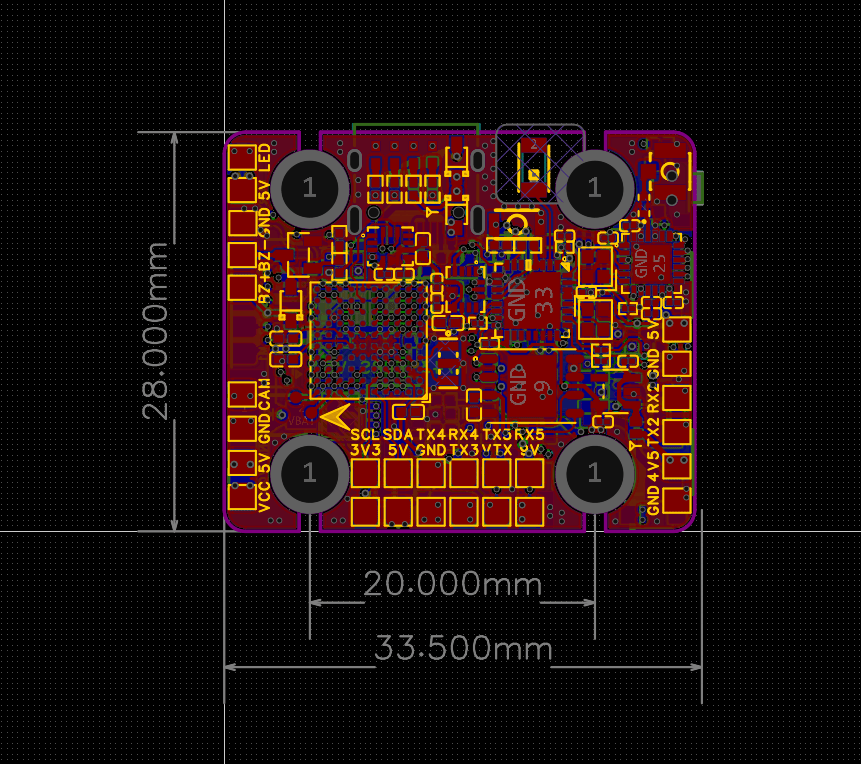
TE H743 MINI
Based on the FMUv6C standard, this compact, high-performance open-source flight controller is equipped with core hardware sourced from the standard Pixhawk 6C. While retaining flagship-level computing power and dual redundant sensors, it significantly reduces the body size. It is specifically designed for small multi-rotor drones, lightweight VTOLs, survey and mapping drones, and research and teaching unmanned platforms, balancing industrial stability and lightweight installation requirements
Specifications
one hundred and twenty-threeSupports up to 4K at 120fps
one hundred and twenty-three1/1.7 inch CMOS
input voltage7.4 - 26.4 V (2S-6S)
Weight (including camera)36.4g
Equipped with a 1/1.7-inch light sensor, a 155° ultra-wide viewing angle, and support for Betaflight's Canvas tuning mode.